Sungjin Cheong

Ph.D. Student in Computer Sciences
WISION Lab · University of Wisconsin–Madison

I'm a second-year Ph.D. student in Computer Sciences at the WISION Lab at the University of Wisconsin–Madison, advised by Prof. Mohit Gupta. My research focuses on computational imaging and computer vision, with an emphasis on:

  • Physics-grounded intelligent sensing and imaging systems
  • ToF/LiDAR computational imaging
  • Statistical signal processing and inverse problems
  • Physics-based and learning-based modeling

Previously, I worked at LG Innotek developing direct Time-of-Flight (dToF) LiDAR signal and image processing algorithms.

I received my M.S. in Mechanical Engineering from Korea Advanced Institute of Science and Technology (KAIST), advised by Prof. Yong-Hwa Park, and my B.S. in Mechanical Engineering from Yonsei University.
Sungjin Cheong
Scroll to view more

Education

University of Wisconsin–Madison Ph.D. in Computer Sciences
Aug. 2025 – Present
KAIST M.S. in Mechanical Engineering
Sep. 2021 – Aug. 2023
Yonsei University B.S. in Mechanical Engineering Military Service (2015–2017)
Mar. 2014 – Aug. 2021

Publications

Ghosts in the Point Clouds
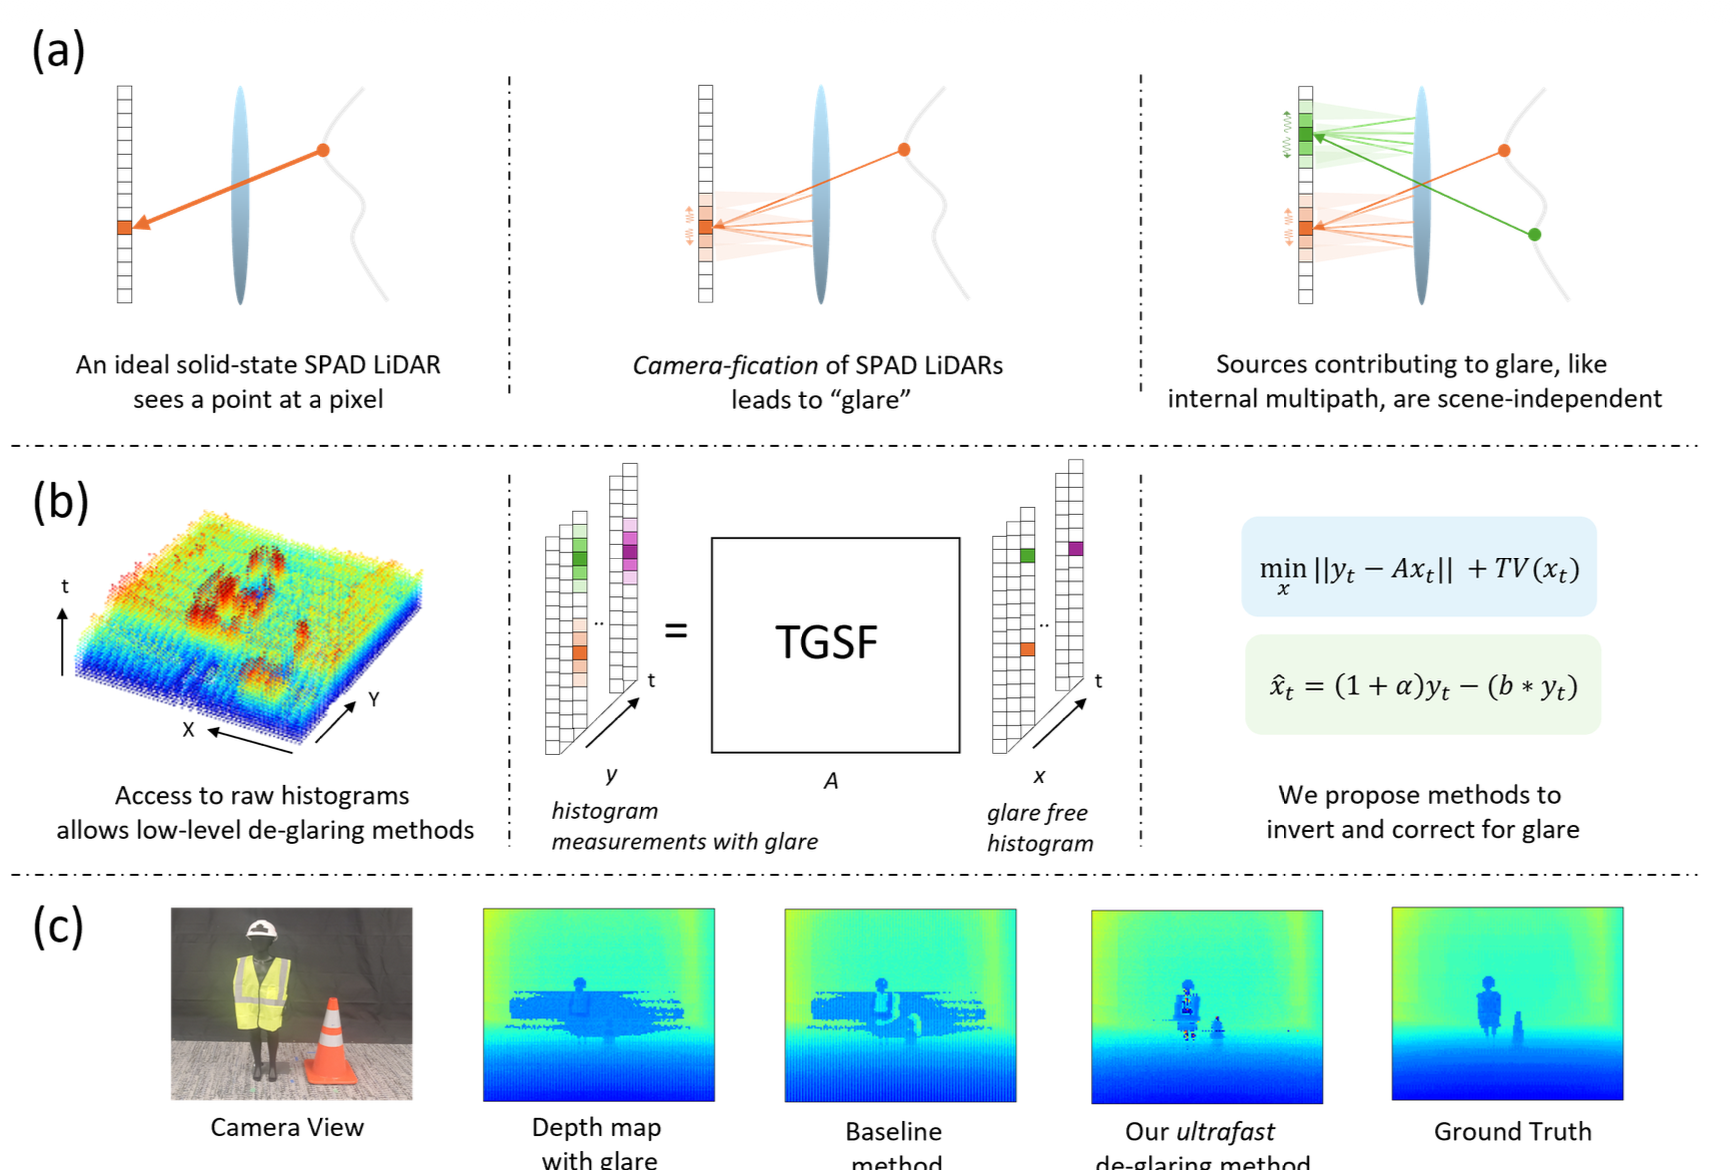
Ghosts in the Point Clouds: De-glaring LiDAR in the Transient Domain
Avery Gump, Connor Andrew Henley, Sungjin Cheong, Akarsh Prabhakara, Mohit Gupta
CVPR, 2026
Thermal-Infrared Remote-Target Detection System
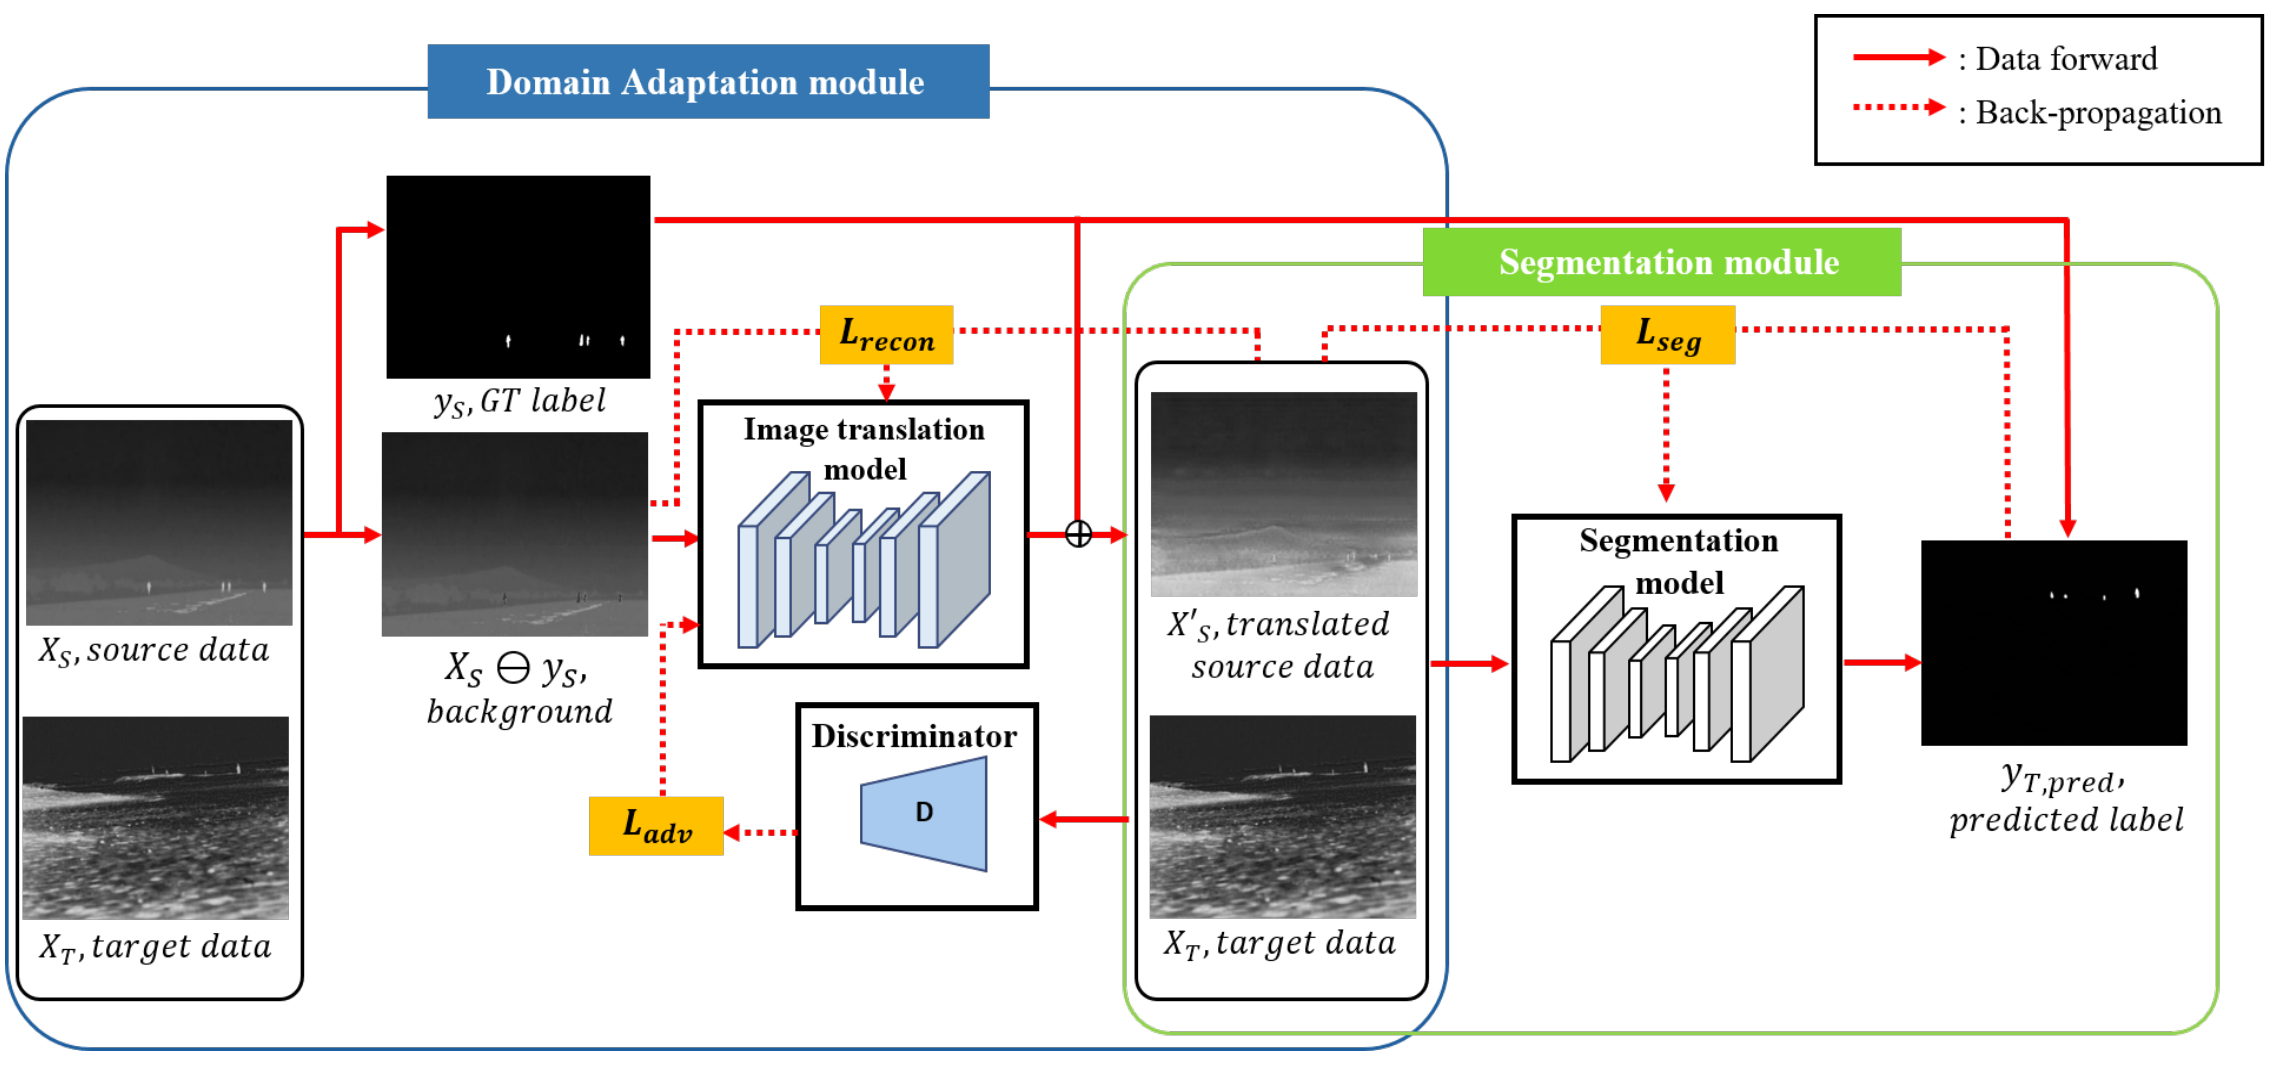
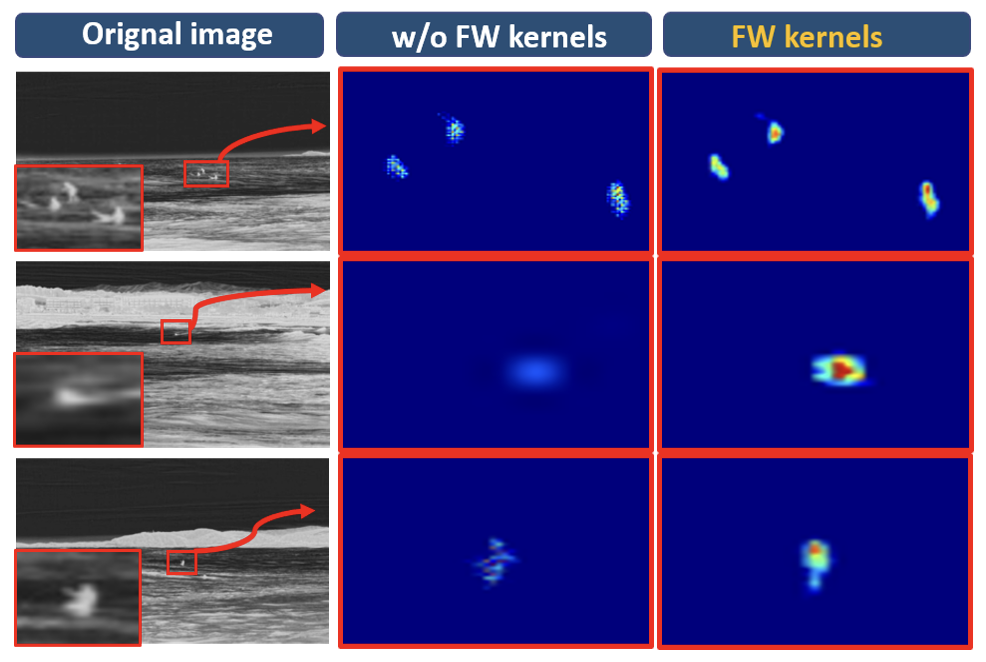
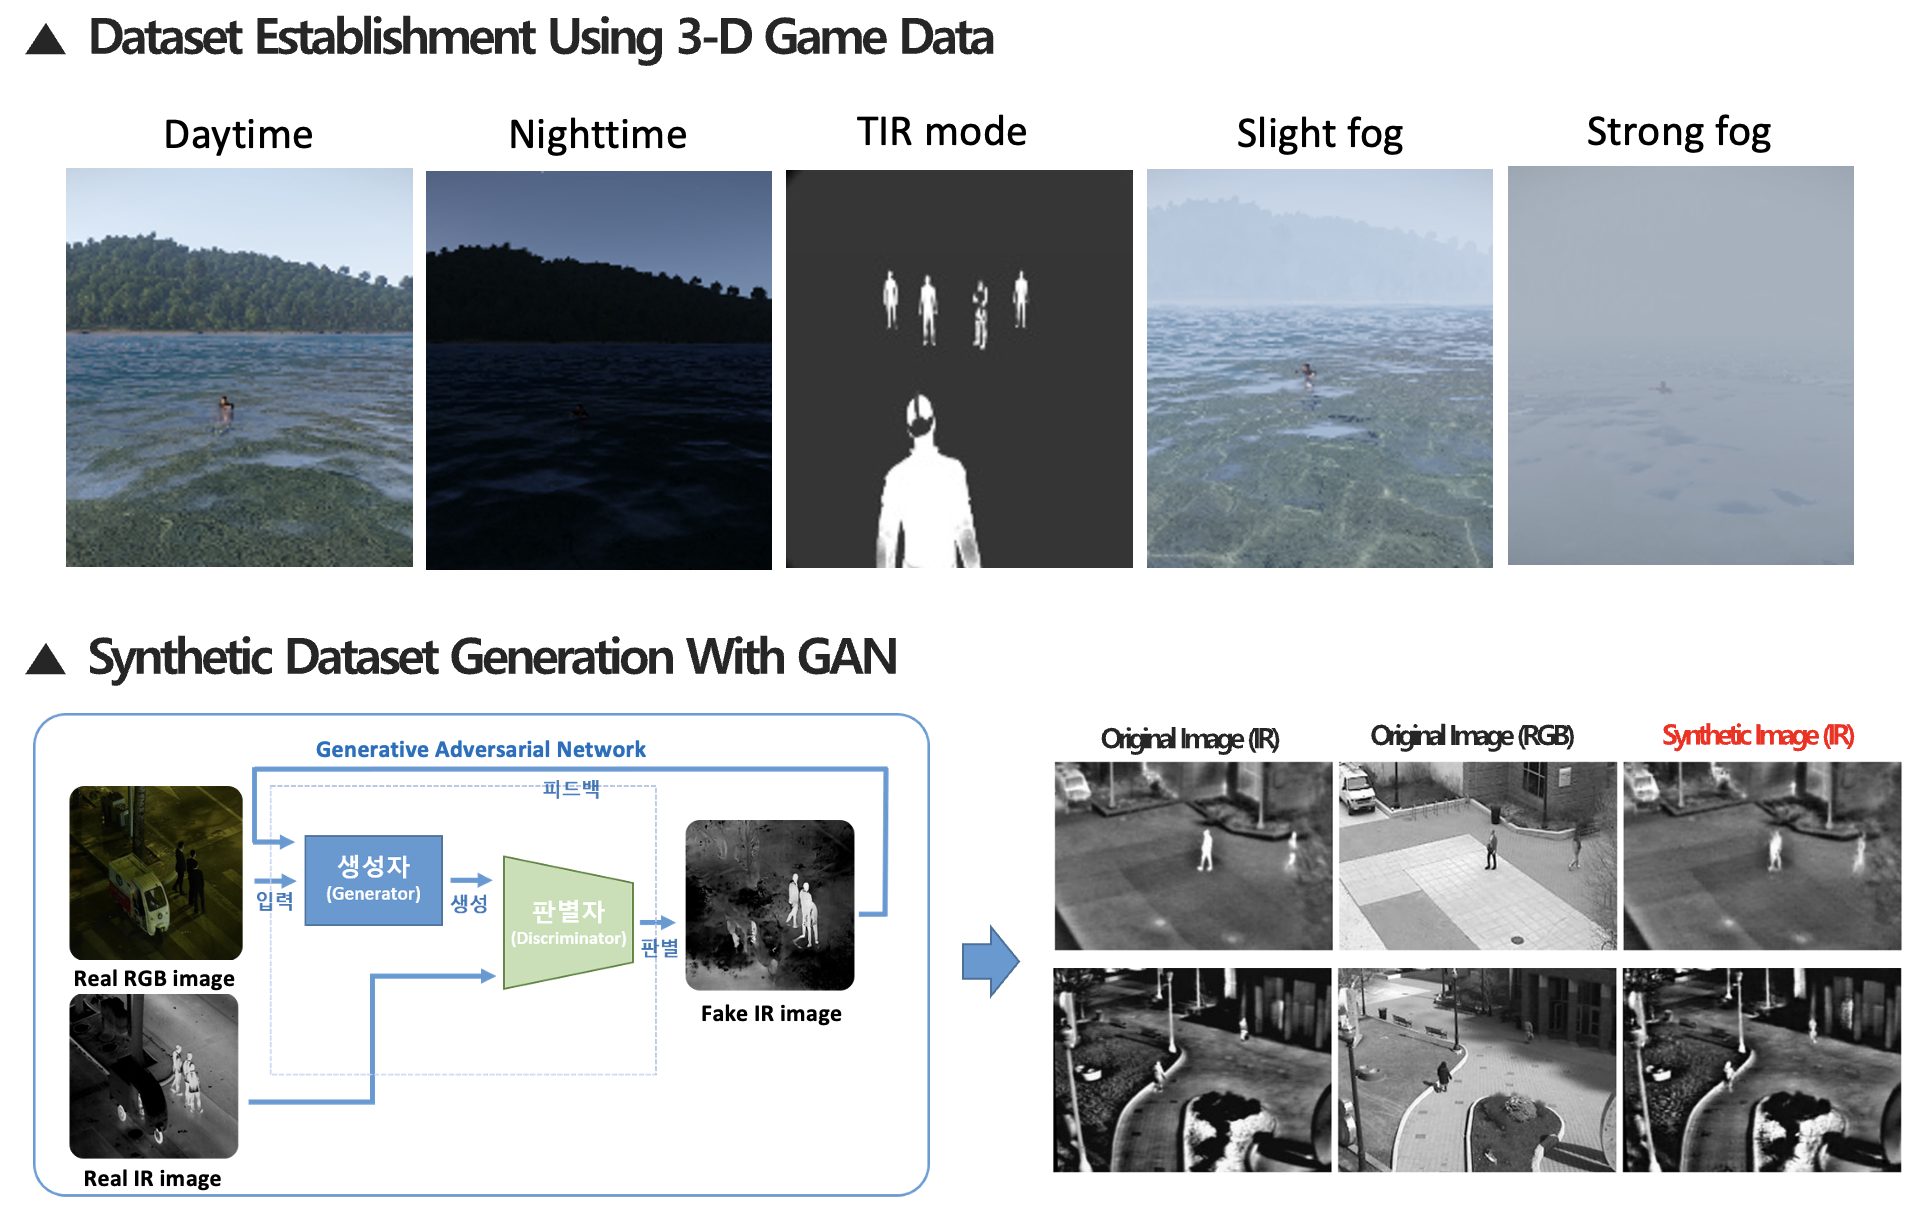
Thermal-Infrared Remote-Target Detection System for Maritime Rescue Using 3-D Game-Based Data Augmentation With GAN
Sungjin Cheong, Wonhu Jung, Yoon Seop Lim, Yong-Hwa Park
IEEE Transactions on Geoscience and Remote Sensing, 2024 (IF: 9.4)
LiDAR Blooming Artifacts Estimation
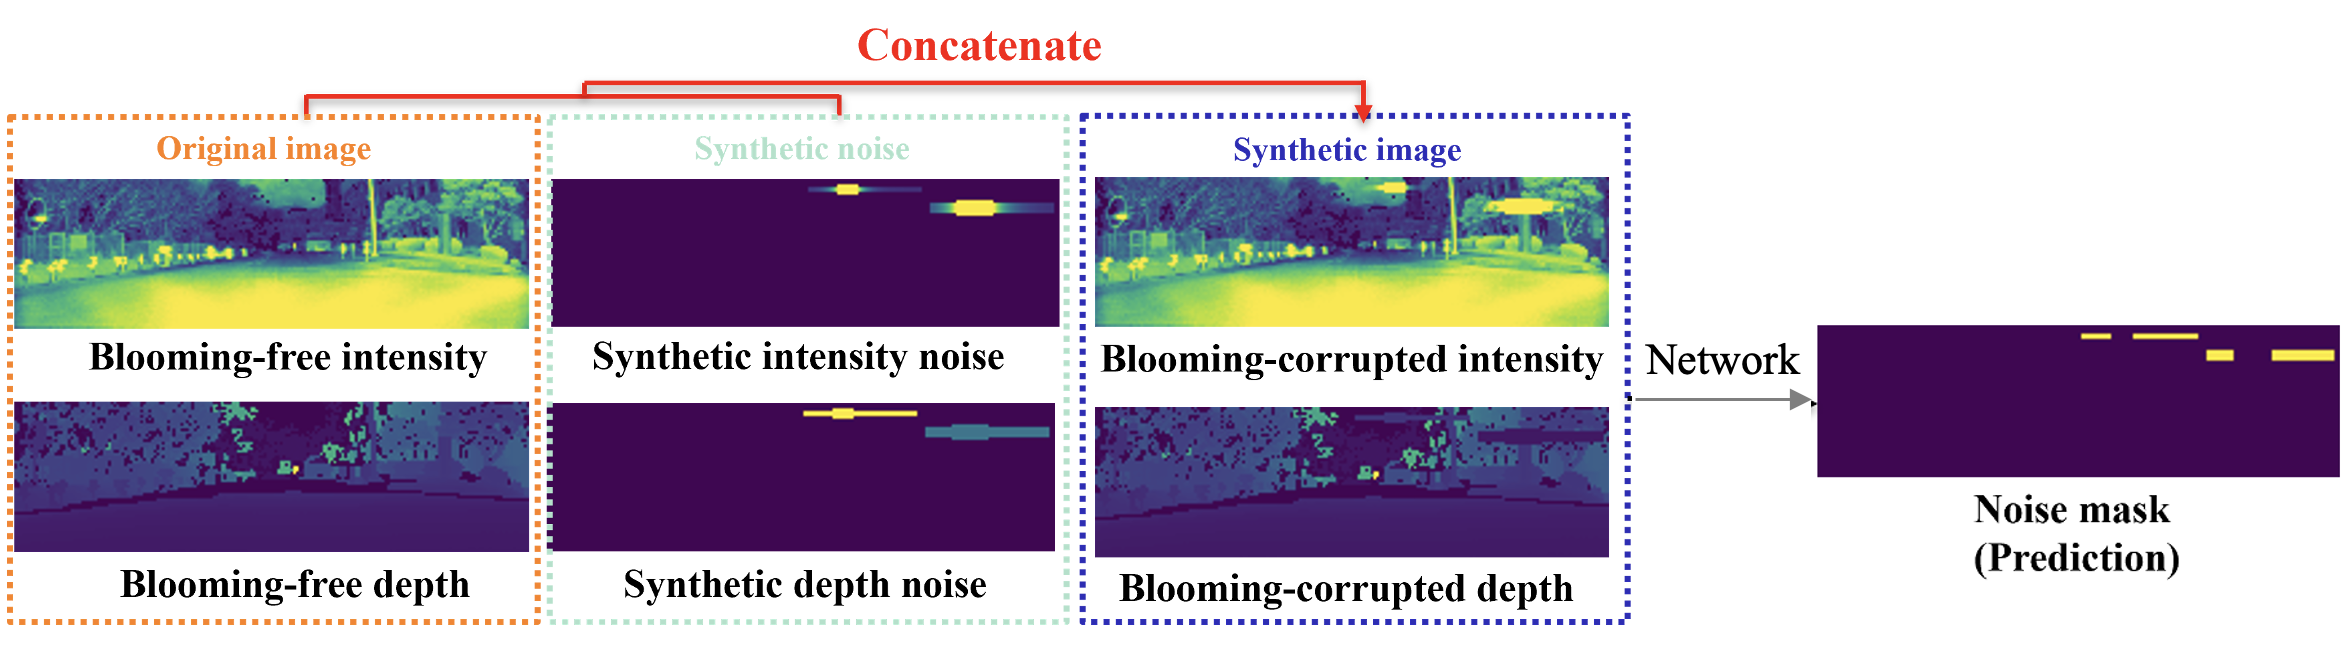
LiDAR Blooming Artifacts Estimation Method Induced by Retro-Reflectance With Synthetic Data Modeling and Deep Learning
Sungjin Cheong, Jusung Ha
ICCE-Asia, 2024
Infrared Image-Based Remote Target Detection
Infrared Image-Based Remote Target Detection for Maritime Rescue Utilizing a Deep Learning Network and Data Augmentation
Sungjin Cheong, Yoon Seop Lim, Wonho Jung, Yong-Hwa Park
Proc. of SPIE, 2023
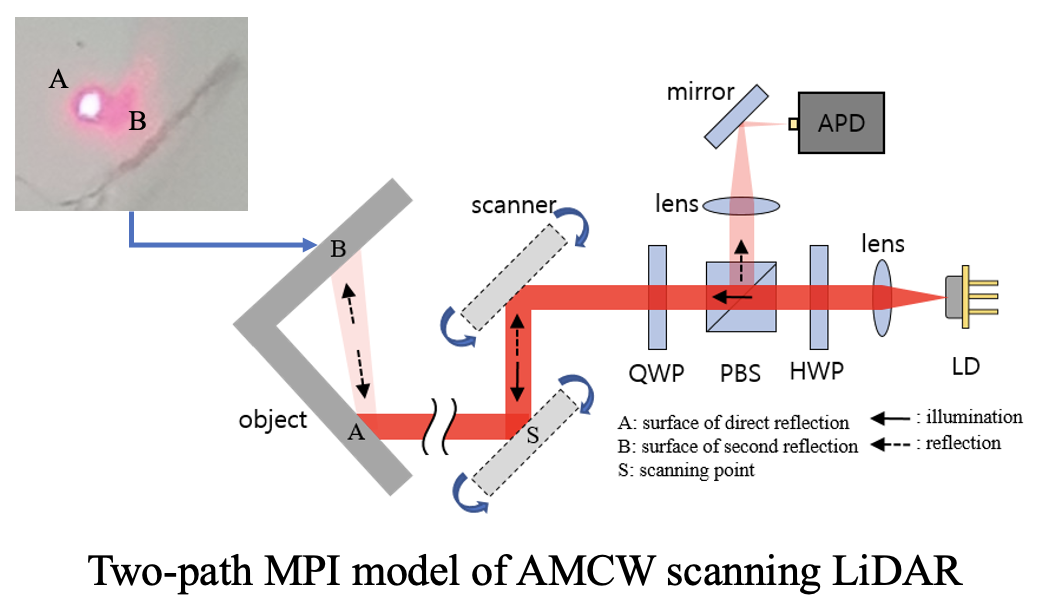
MEMS-Based Indirect Time-of-Flight Scanning LiDAR
MEMS-Based Indirect Time-of-Flight Scanning LiDAR With Parallel-Phase Demodulation and Multipath Interference Suppression
Sunghyun Lee, Yoon Seop Lim, Sungjin Cheong, Yong-Hwa Park
Proc. of SPIE, 2023
Long-Distance 3D Face Recognition
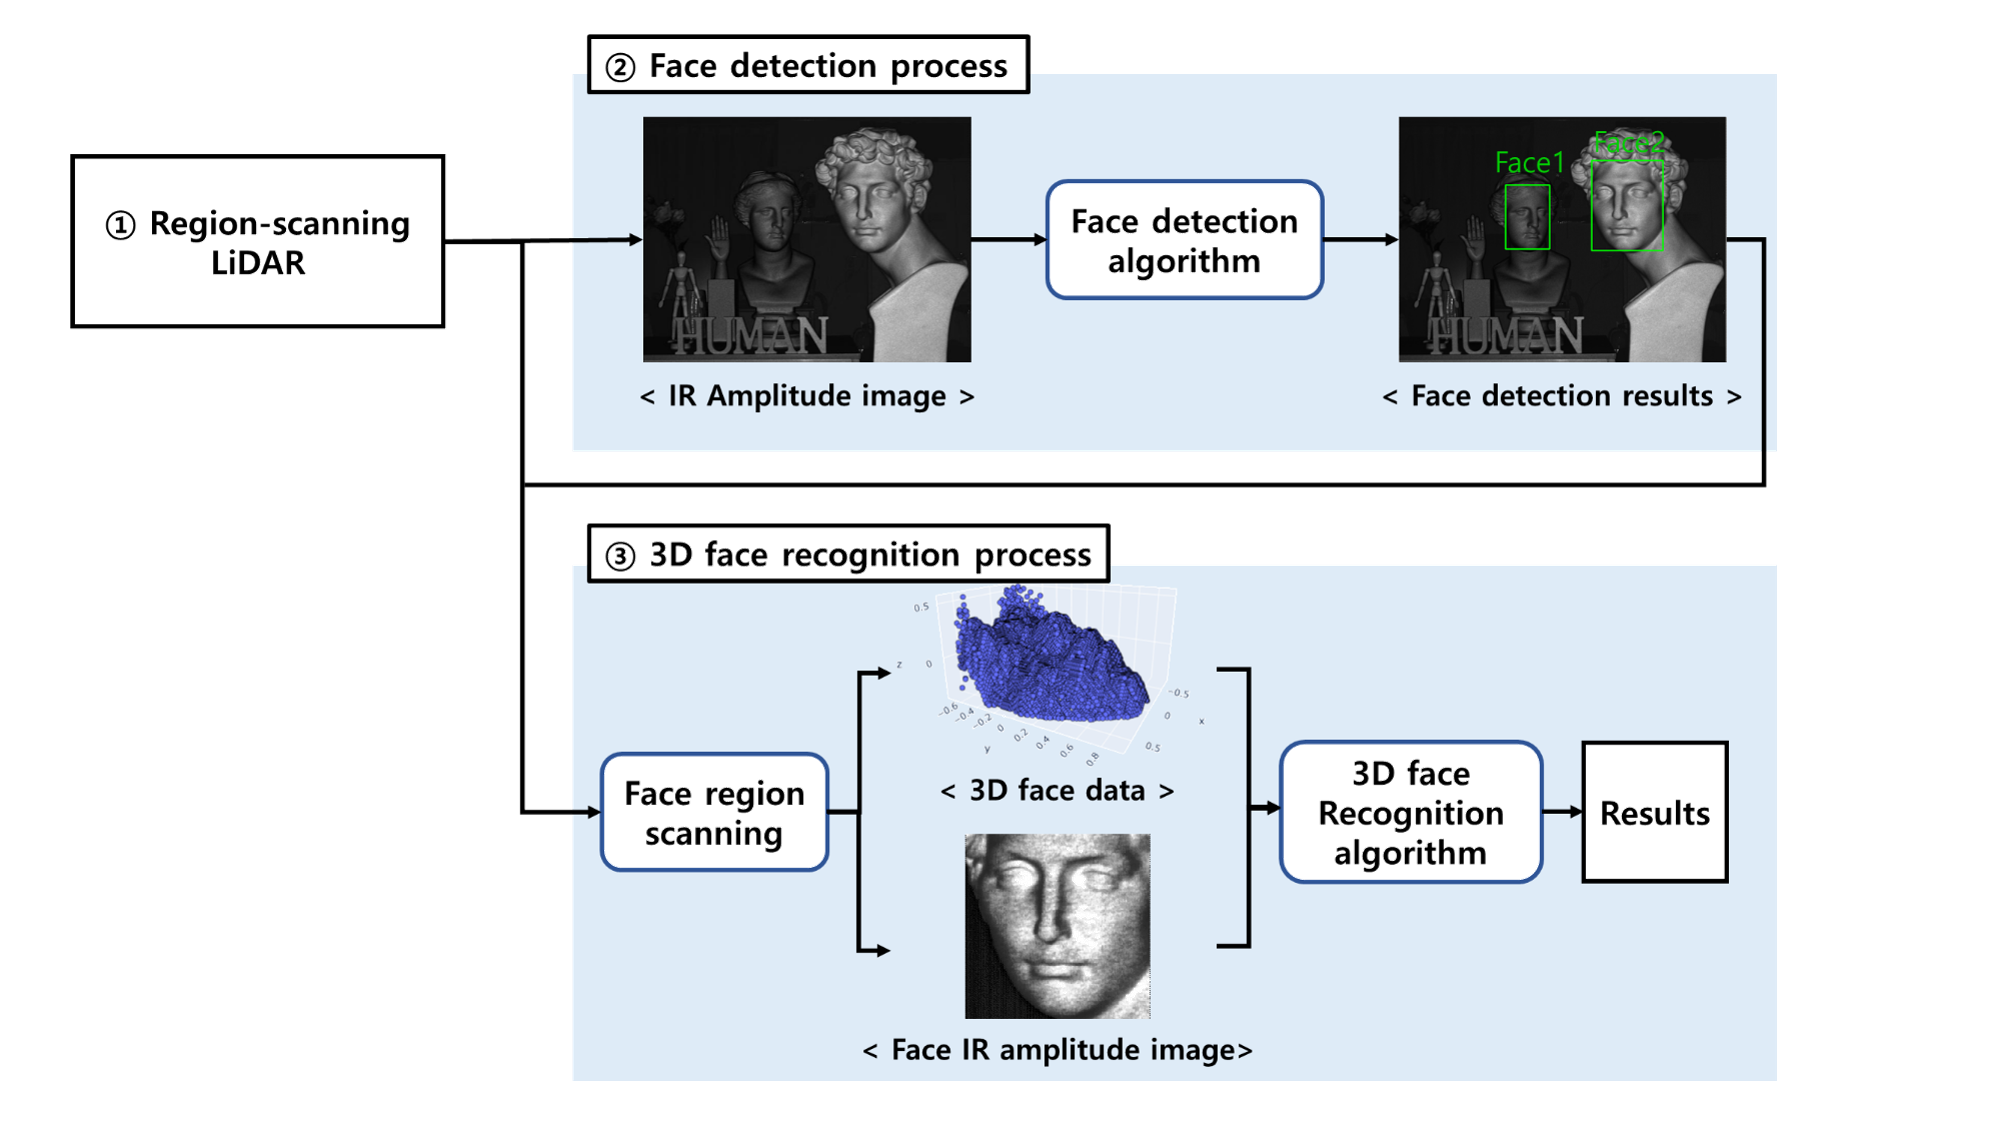
A Long-Distance 3D Face Recognition Architecture Utilizing MEMS-Based Region-Scanning LiDAR
Yoon Seop Lim, Sunghyun Lee, Sungjin Cheong, Yong-Hwa Park
Proc. of SPIE, 2023
Head Pose Estimation
Head Pose Estimation Method Using Depth Camera Based on 3D Point Cloud
Sungjin Cheong, Sunghyun Lee, Yoon Seop Lim, Yong-Hwa Park
Conference of The Korean Society of Mechanical Engineers, 2022
Validation of Simulation Model for 3D iToF Sensor
Validation of Simulation Model for 3D Indirect Time-of-Flight Sensor
Sunghyun Lee, Yoon Seop Lim, Sungjin Cheong, Yong-Hwa Park
Conference of The Korean Society of Mechanical Engineers, 2022
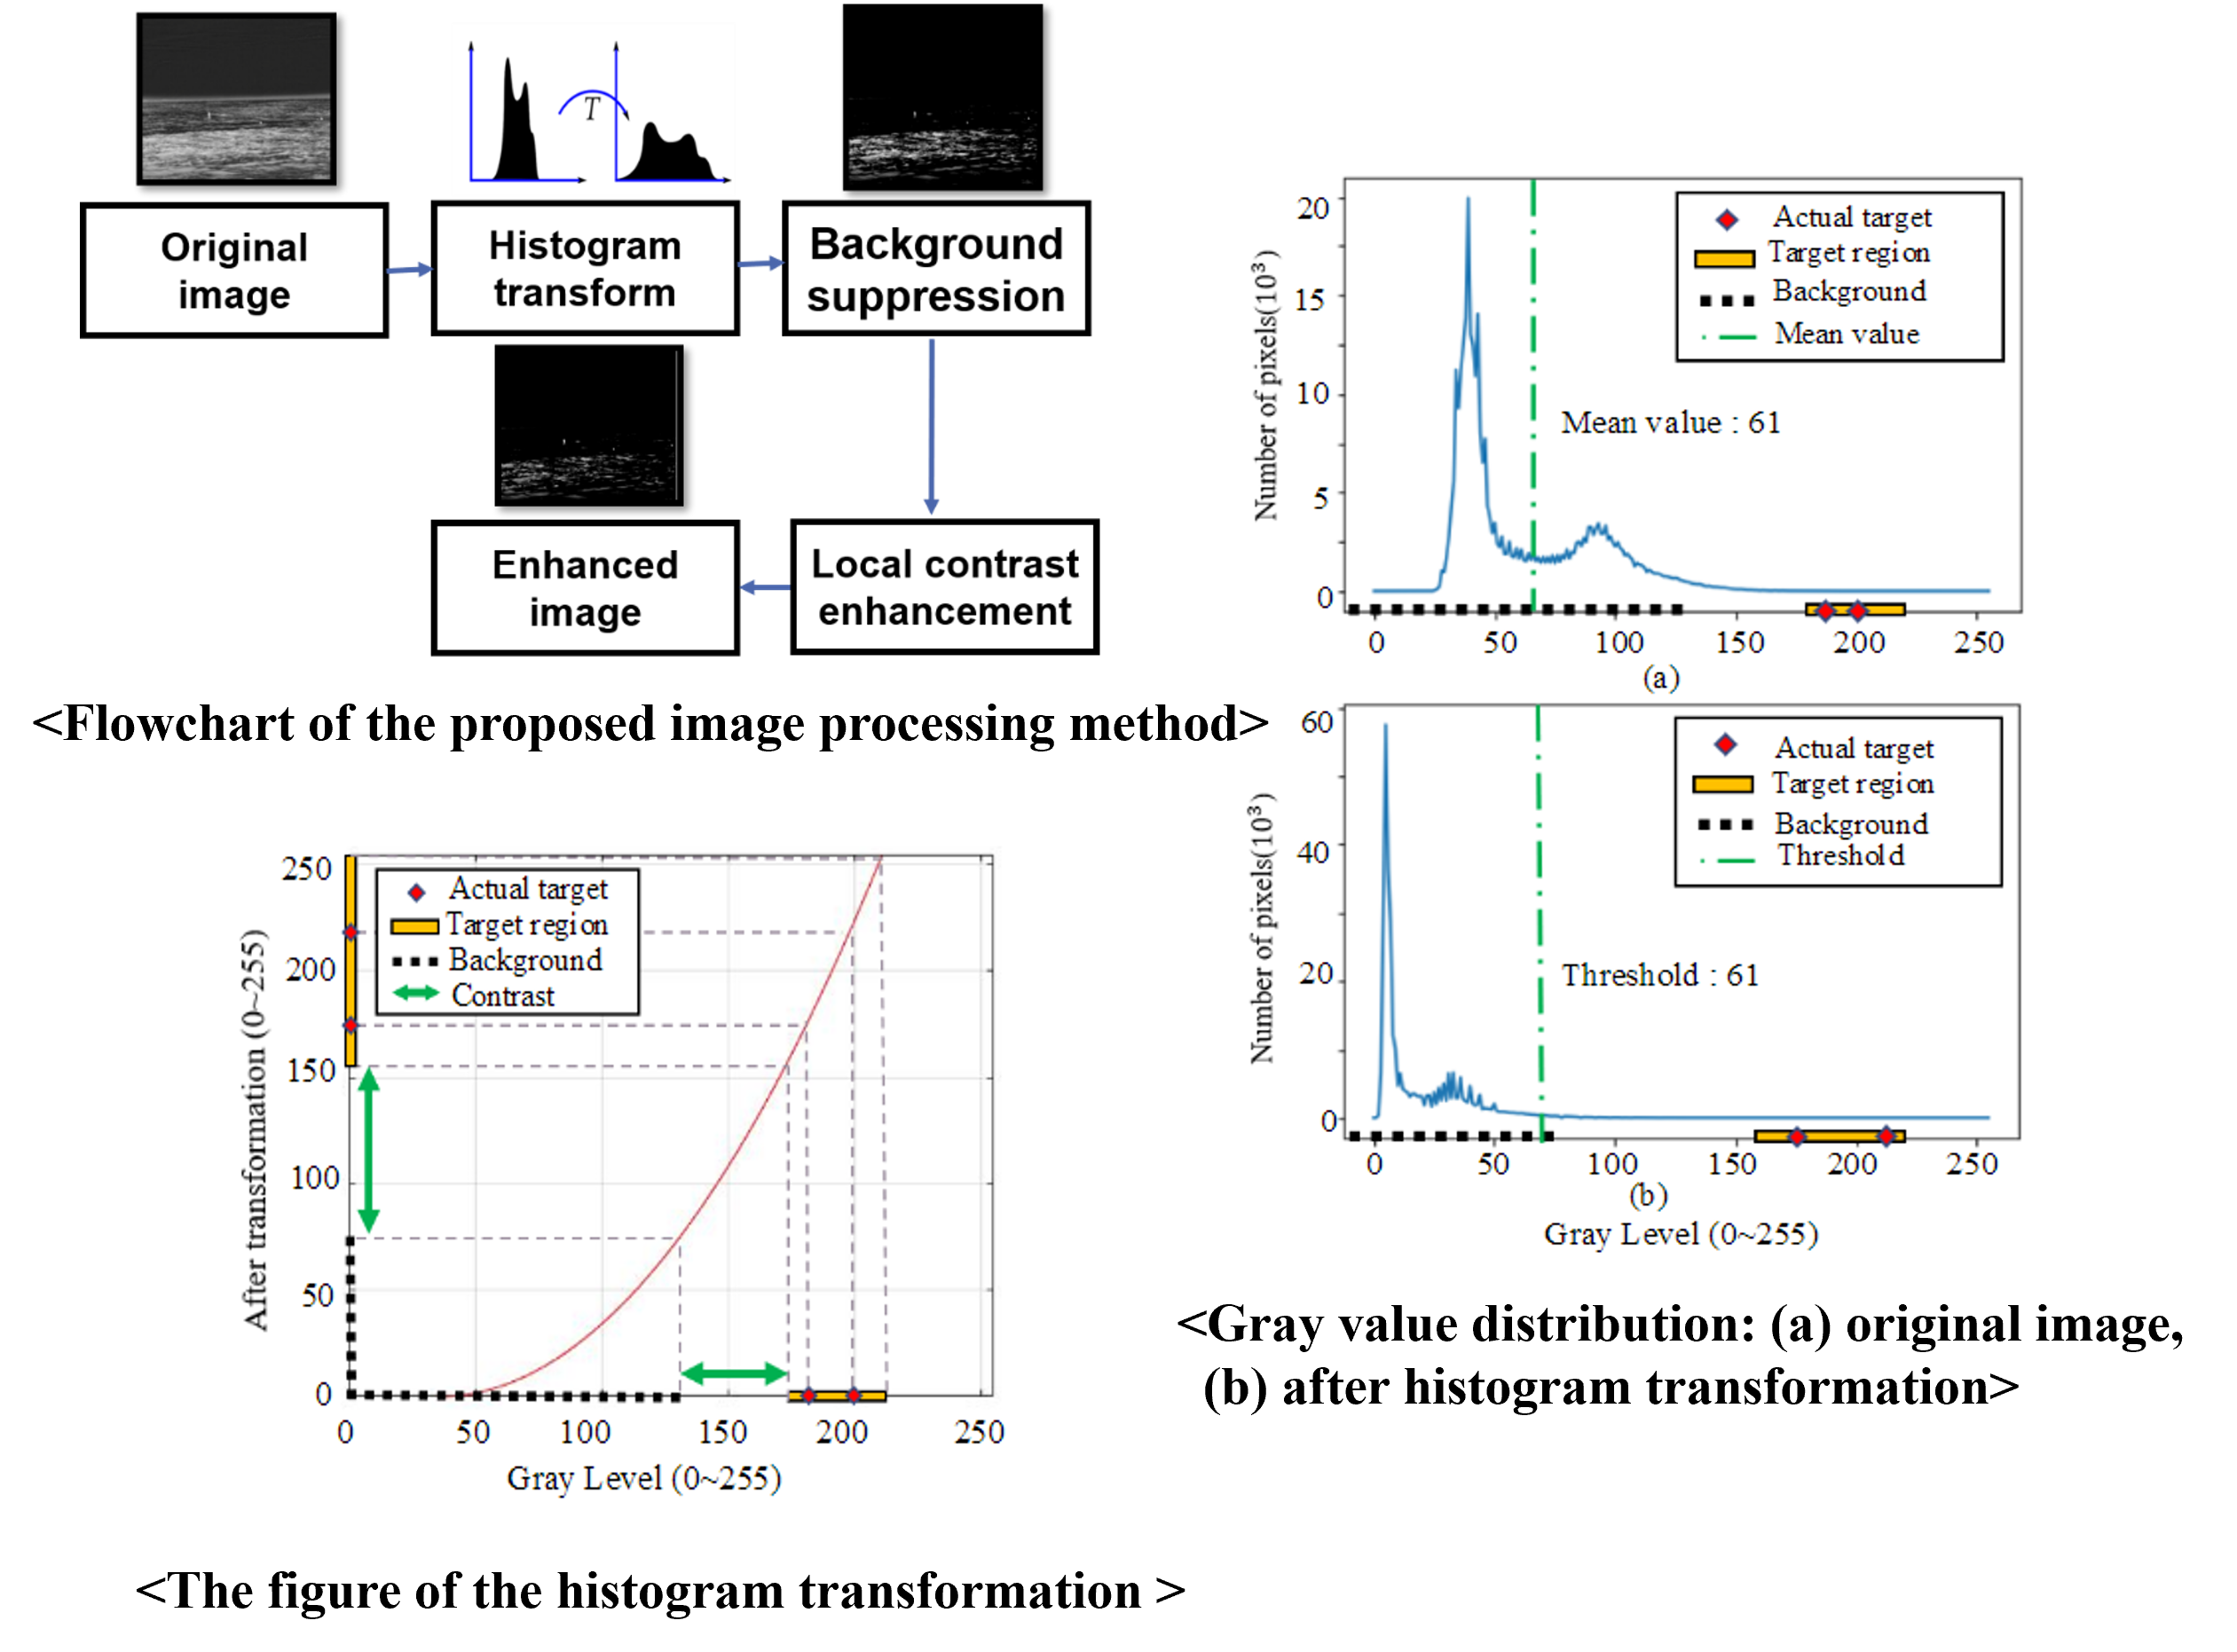
Infrared Small Object Detection
Infrared Small Object Detection Based on Histogram Transformation
Sungjin Cheong, Wonho Jung, Yong-Hwa Park
Conference of The Korean Society of Mechanical Engineers, 2022
Depth Image Super Resolution
Depth Image Super Resolution Method for Time-of-Flight Camera Using Single Image Depth Estimation
Yoon Seop Lim, Sunghyun Lee, Sungjin Cheong, Yong-Hwa Park
Conference of The Korean Society of Mechanical Engineers, 2022
Depth Error Correction of 3D Scanning Sensor
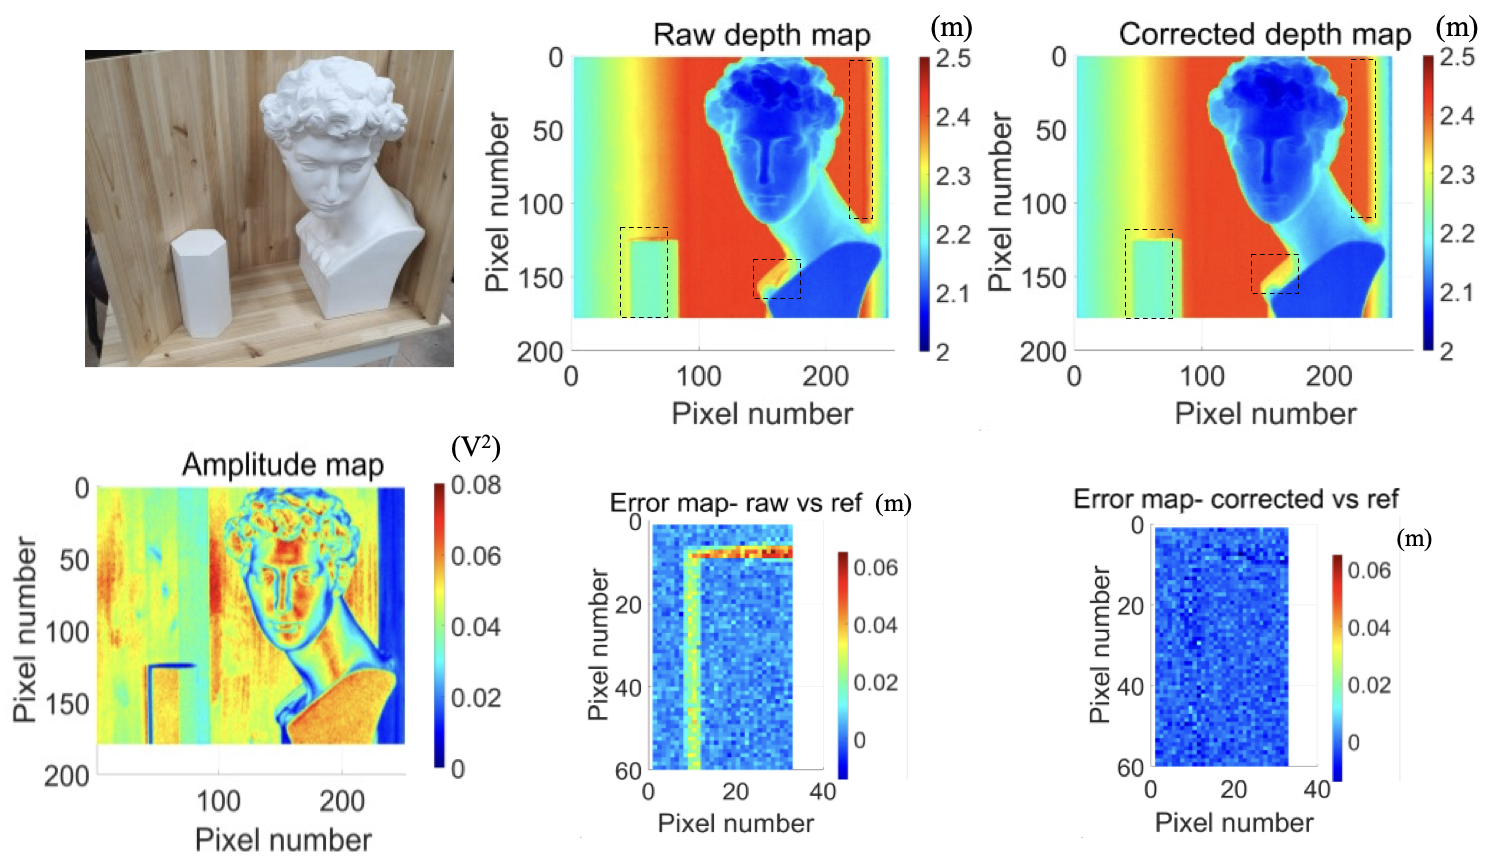
Depth Error Correction of 3D Scanning Sensor Using Machine Learning
Sunghyun Lee, Yoon Seop Lim, Sungjin Cheong, Yong-Hwa Park
Conference of The Korean Society of Mechanical Engineers, 2022

Past Projects

Autonomous driving education with CARLA
Educational Content for Autonomous Driving with CARLA
Divine Technology Inc., Seoul, Republic of Korea
Achieved Outcomes: Produced online educational material and corresponding CARLA simulation practice code targeted to undergraduate and graduate school students, consisting of perception, decision, and control.
(Role: Camera, LiDAR perception part including lane detection, calibration, 2D/3D object detection, tracking etc.)
Radar, LiDAR and camera integrated platform
Radar, LiDAR, and Camera Sensor Integrated Platform
LG Innotek Inc., Seoul, Republic of Korea
Achieved Outcomes: Develop integrated automotive sensors software platform.
(Role: (Full) 3D data processing, LiDAR noise filtering, Human & Object tracking algorithm, (Partly) Integrated sensor setup in vehicle, Viewer GUI)
Infrared monitoring AI system for maritime rescue
Infrared Monitoring AI System For Maritime Rescue
Korean Coast Guard, Incheon, Republic of Korea
Achieved Outcomes: Designed thermal-infrared target detection system specified for unmanned coast guard boats for maritime rescue search tasks.
(Role: Project leader, Dataset acquisition, Experiment, Overall framework design)
iToF scanning LiDAR platform
iToF Scanning LiDAR Platform and Its Application Software
Intek Plus Inc., Daejon, Republic of Korea
Achieved Outcomes: Proposed miniaturized indirect time-of-flight AMCW LiDAR system and its application software tailored to driver monitoring system (DMS) and highly precise 3D scanner.
(Role: (Full) 3D computer vision, (Partly) Optical system design & Signal processing)